MagicLab Robotics
MagicDog
MagicLab Robotics

MagicDog

A programmable quadruped for robotics education, interactive demonstrations and mobile robotics development. Explore MagicDog through The Robot Group’s Official MagicLab Robotics Commercial Route, with the configuration and software access selected around your teaching, research or engagement project.
Key industrial use cases
Robotics education; perception and navigation experiments; human–robot interaction; science outreach; interactive demonstrations; software development with an SDK-enabled configuration.
Request Assessment
MagicDog

Robot overview

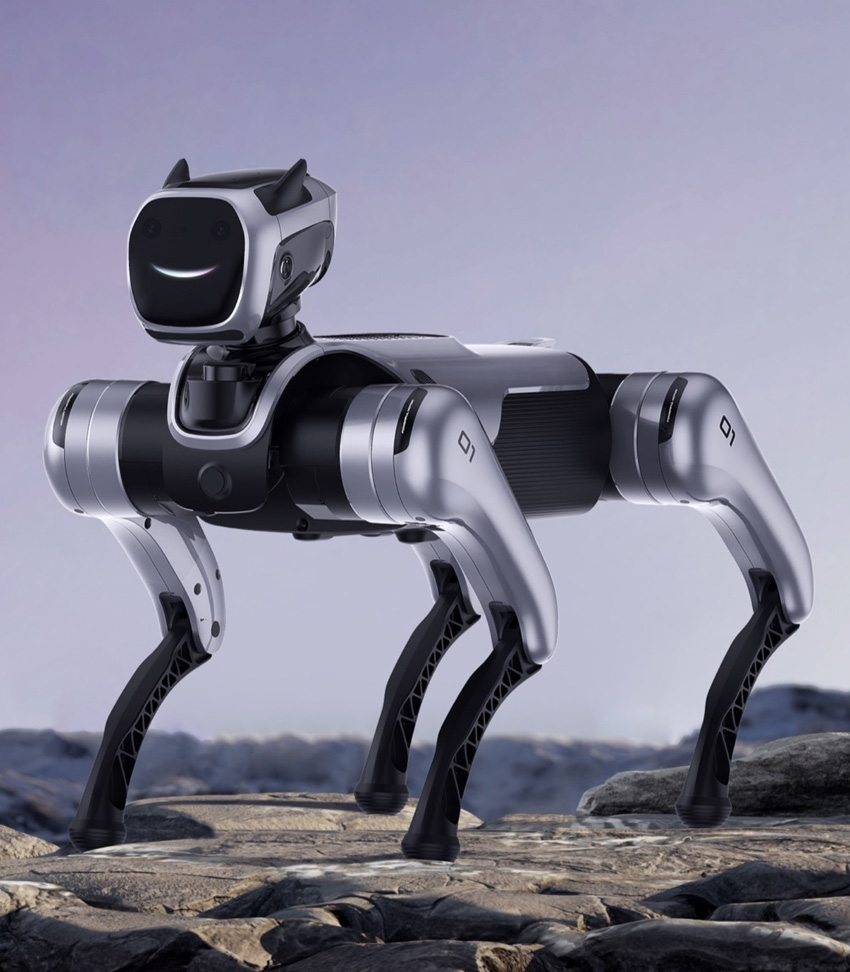
MagicDog combines quadruped movement with sensing and interactive behaviours in a compact robot format. It can give students a visible way to connect programming decisions with physical actions, or provide an engaging platform for a supervised demonstration.

Graphical programming supports an accessible starting point. Teams requiring deeper software development should assess the EDU configuration and its SDK provision against their course or research requirements.

The Robot Group helps UK organisations select the configuration, scope a useful first exercise and understand pricing, software access and manufacturer support.
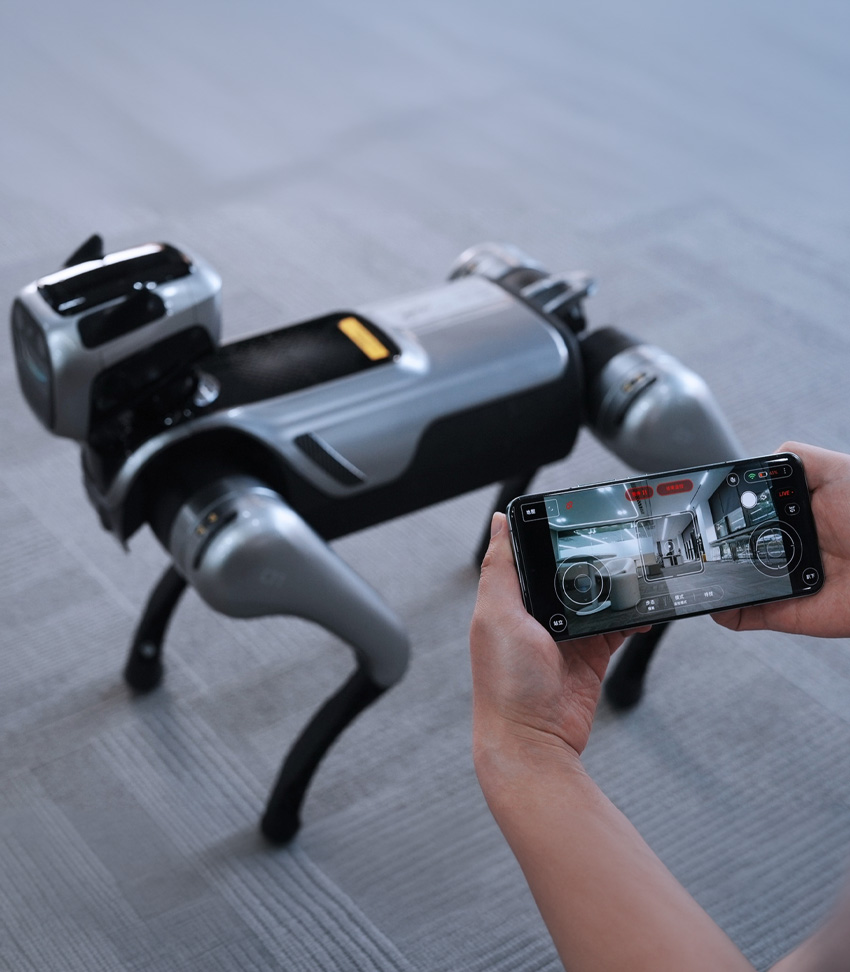
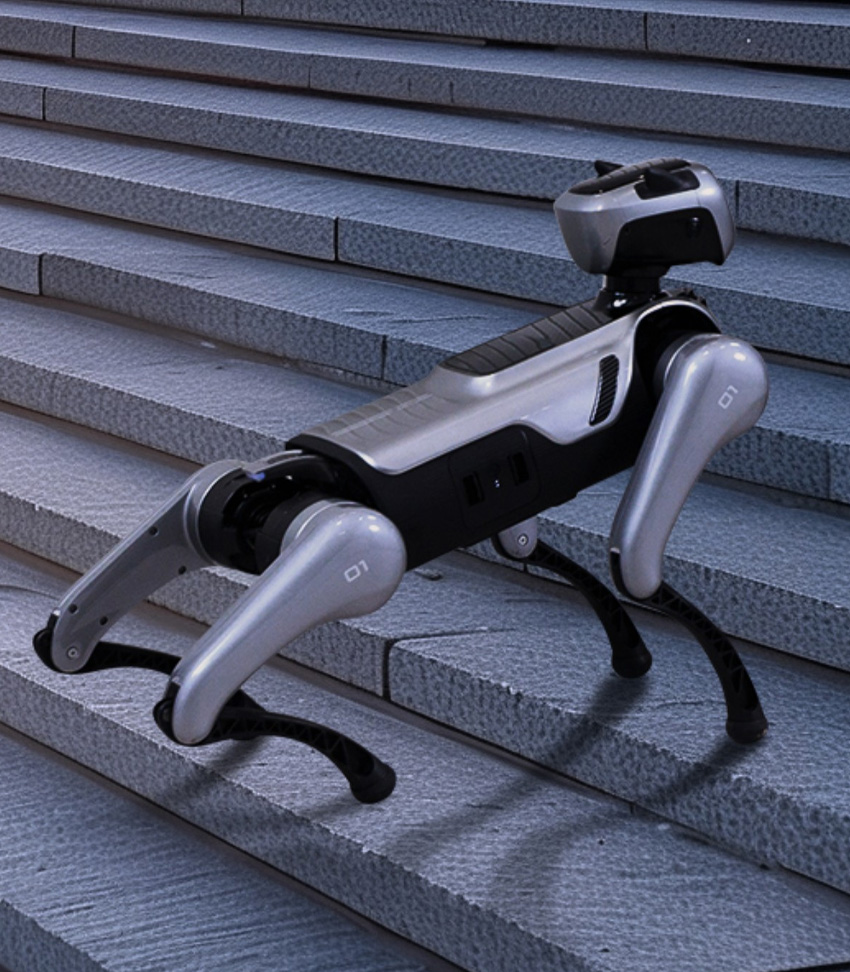
See MagicDog in action

Request Assessment
MagicDog
Key

Technical Breakthroughs

1. Coordinated movement across 13 joints

Twelve leg joints and an articulated head provide 13 degrees of freedom. Built-in movement routines offer a starting point for demonstrations and teaching exercises, helping users examine how changes in posture and movement affect the robot’s behaviour.

2. Graphical programming for practical learning

MagicDog supports graphical programming for creating and arranging behaviours. A teaching programme could begin with a short movement sequence, then ask students to change the sequence and explain the resulting physical response.

3. SDK and ROS 2 resources for development

MagicLab lists SDK support on MagicDog EDU and publishes Python, C++ and ROS 2 documentation. Supported interfaces cover motion, sensor information and robot status, with resources for mapping and navigation. We confirm access for the selected configuration.

Explore MagicDog developer documentation

4. Onboard sensing and visual capture

LiDAR, depth and other cameras provide inputs for perception and obstacle-response work. A head-mounted 4K camera also supports image and video capture. The sensor configuration should be checked against the data your application needs.

5. Interaction through voice, vision and touch

MagicDog combines voice, visual and touch inputs with expressive head and body movement. These capabilities provide material for interaction design and engagement projects. Define the required responses and any connected voice services as part of the proposed application.

MagicDog

Deployment

+ Scalability

Choose a first outcome that the team can demonstrate and measure. For education, that might be a repeatable programming exercise. For research, it could be a navigation or interaction experiment with recorded results.

The Robot Group helps establish:

  • PRO or EDU configuration and required SDK access.
  • Teaching objectives, development skills and relevant examples.
  • Required sensor data, interaction functions and network access.
  • Operating area, supervision, charging and handling arrangements.
  • Acceptance measures, documentation and manufacturer support.

‍

A successful first exercise can become a repeatable teaching activity or a starting point for more advanced software development.

UK enquiries and evaluation planning are open. Pricing, delivery and support arrangements are confirmed for each project.

Direct access to leading humanoid OEMs; at the industry’s best rates.

The Robot Group is an independent adviser. Brand names and products are referenced for comparison.
‍
All trademarks are the property of their respective owners. Availability and UK compliance subject to OEM confirmation.
Humanoid performing parts kitting tasks
Ready to deploy humanoid robots in your business?